Claim
Momentum transfer is cheaper to modulate than the high-power magnetic fields used for electromagnetic acceleration
Evidence
A major challenge for electromagnetic space launchers is the enormous rate at which the accelerated mass gains kinetic energy near the end of the launcher. In the reference design, this mass—called the launch train—comprises the spacecraft, launch sled, and adaptive nut. Its combined mass is 38,940 kg, its speed at the end of the horizontal acceleration section is approximately 11,120 m/s, and its acceleration is 80 m/s². Its peak rate of kinetic-energy gain is therefore
As v=0 at t=0, the kinetic-energy gain at t=0 is also zero. So the rate of kinetic energy gain starts at zero and increases linearly to 34.6 GW during the launch event.
This peak rate is equivalent to the power output of about 17 Hoover Dams, or roughly one quarter of the exhaust kinetic power of the Starship V3 Booster (see calculation below).
The launcher must deliver this mechanical power to the launch train. How it stores, transfers, and controls that energy has major implications for the cost of its power-handling equipment. If the launch system is made up of a number of discrete segments, then the power handling capacity of the individual segments will depend on the launch train's speed when it is alongside the segment.
If each segment is the same length, then, assuming constant acceleration, each segment transfers the same amount of energy to the launch train. Plotting the segments' power-handling capacity versus position gives a triangle (see below), and the triangle's area represents the system's total power-handling capacity.
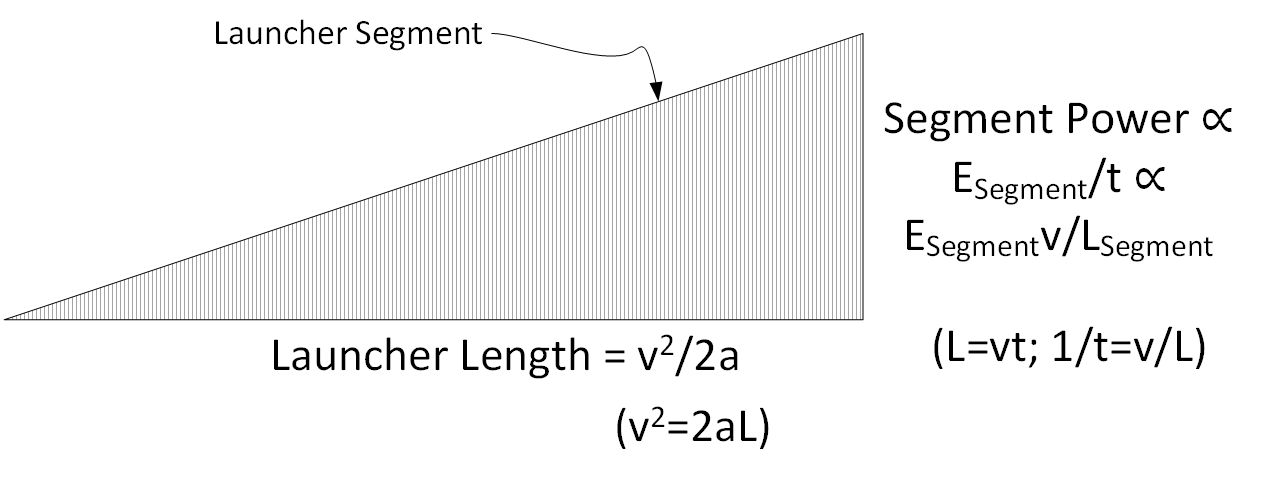
At first blush, the total capital cost of the power-handling equipment appears prohibitively expensive. This is, in fact, a well-known concern for many past electromagnetic launcher designs and has sometimes been referred to as "the switching problem".
Understanding the relationship between a mass driver's exit velocity and its cost is critical to evaluating its economic feasibility. In many electromagnetic mass-driver architectures, cost grows rapidly with exit velocity because the system must generate, switch, and control very large electromagnetic fields during the launch event. Some architectures therefore tend toward cost scaling that is closer to velocity cubed. The variable-pitch screw launcher avoids this by storing energy mechanically before launch and then transferring that energy to the launch train through mechanical momentum transfer during launch.
The claim compares: a) the screw launcher's conversion-in-advance followed by on-the-fly momentum transfer mechanism for accelerating a spacecraft, to b) the traveling magnetic-field mechanism used in a conventional linear electric motor. In both cases, during the brief moment that the spacecraft interacts with a given segment of the launch system, something is rapidly modulated. In the traditional linear electric motor-based system, power electronics modulate electric currents to generate traveling magnetic fields that propel the vehicle forwards. In the screw launcher's case, a fast electromagnetic clutch modulates the transfer of momentum from a flywheel to the screw.
The term "cheaper to modulate" means that the equipment that modulates momentum transfer (the electromagnetic clutches) in the screw launch system is cheaper to implement than the equipment that does the current and magnetic field modulation in a linear electric motor system. To support this claim, we'll first examine how much power is being modulated in each case, and then we will apply conversion factors to account for the relative cost of modulating the power. This approach roughly estimates the relative cost without requiring a full bottoms-up accounting of all the component and subsystem costs in each case.
This claim builds on the related Evidence Ledger claim, "Momentum Transfer from the Flywheels, through the Screws, to the Adaptive Nut is Feasible." That claim analyzes the transfer of rotational kinetic energy from internal flywheels into the rotating screws, and then from the screws into the adaptive nut and launch train. The present claim focuses on the economic implications of that mechanism: the expensive, fast-gated element is not required to generate the full launch power electromagnetically. Instead, it modulates the transfer of pre-stored mechanical momentum.
However, before jumping into the math, let's build an intuitive sense of what happens during momentum transfer. Consider an astronaut on the International Space Station catching a baseball traveling along the orbital path, retrograde, at a relative speed of 40 m/s. Relative to the Earth, the baseball's kinetic energy is
The catch will change the ball's velocity by , so after the catch the baseball's kinetic energy is
The astronaut adds to the ball in a small fraction of a second. If we assume the catch took 0.1 seconds, then the power associated with the catch is ...
... or roughly half a megawatt or 595 horsepower. There's no way the astronaut's arm is generating even one-thousandth the power of a high-end sports car, so how do we explain what's going on here?
The key insight that resolves this paradox is that kinetic energy is frame-dependent: when fast-moving objects exchange momentum, the apparent energy transfer depends on the observer’s frame. In the Earth-centered frame, the baseball appears to gain 44 kJ. But in the astronaut’s local frame, the baseball was simply a 0.145 kg object moving at 40 m/s, with only 116 J of kinetic energy to absorb.
So how does this apply to the momentum transfer between the flywheels and the screws?
First, since both the flywheel and the screw are spinning rapidly in the same direction, the power associated with the kinetic energy transfer needs to be evaluated in the screw's spinning reference frame, not the static reference frame. The flywheel spins only slightly faster than the screw, so in the screw's reference frame, the flywheel spins relatively slowly. When the clutch activates, it "applies the brakes" to the flywheel, slowing it down until it's spinning at the same speed as the screw. The kinetic energy transfer in the screw's reference frame, and thus the power absorbed by the electromagnetic clutch, is relatively small.
Second, a braking system is cheaper to implement than a drivetrain. For example, Toyota quoted approximately $51,000 for the GR86 drivetrain, which delivers 228 hp (170 kW). Toyota quoted approximately $5,000 for the braking system. The GR86 weighs about 1,301 kg and can stop from 100 km/h in roughly 37.5 m. The peak braking power at the start of the stop is approximately
Using , , and gives a peak braking power of about 372 kW. The drivetrain therefore costs about $0.30/W, while the braking system costs about $0.013/W. On this basis, implementing braking power costs roughly 1/22 as much as implementing drivetrain power.
Third, the electromagnetic clutches apply braking action only for a very brief time. The earlier referenced claim determined that the clutches in the last screw segment activate for only 9 milliseconds each time a spacecraft is launched, so if 540 spacecraft are launched over the life of the system, this segment's electromagnetic clutches are active for a total of
A braking component designed to operate for a total of only 4.9 seconds in a hermetically sealed, contaminant-free environment should be cheaper to engineer than an automotive brake system, which is engineered to not only last much longer, but must also endure a wider range of temperatures, mechanical stresses, vibrations, and environmental contaminants.
To summarize, even though the launch train gains kinetic energy at a rate of 35 GW by the time it reaches the end of the horizontal acceleration section, the electromagnetic clutches in the last segment are far cheaper than the cost of an electric machine designed to convert electric energy into kinetic energy for three reasons: 1) The energy transfer between the flywheels and screws is much lower when observed in the spinning screw's reference frame, 2) The per-watt cost of a braking system is roughly 1/20th the cost of a drive system, 3) The design requirements for the braking system (that is, operational life, environmental conditions, etc.) are easy to meet when compared with the requirements for typical automotive brakes.
Next, let's examine the flywheel-to-screw momentum transfer quantitatively.
In a conventional electromagnetic accelerator, the system delivers this level of power to electric machinery that generates and controls the accelerating electromagnetic fields that propel the payload forward. That does not merely require energy; it requires high-power electrical machinery, pulsed-power systems, switching hardware, conductors, magnetic structures, cooling systems, insulation, and control systems capable of operating at very high instantaneous power.
The screw launcher separates these functions. Electrical energy is gradually converted into mechanical kinetic energy for several minutes (possibly 20 minutes) before each launch. It stores that energy in rotating screws and internal flywheels. The total energy converted is
If this energy is supplied over 20 minutes, then the total power required to recharge the system is
The electric-to-kinetic power conversion hardware requirements for the entire system (2.375 GW) are a small fraction of the power conversion hardware requirements of the last segment of a linear motor type architecture (34.6 GW).
During launch, the fast-gated element is an electromagnetic clutch that modulates the transfer of angular momentum from the flywheel into the screw. The clutch sees the relative slip power between the flywheel and the screw, not the full inertial-frame kinetic-energy gain of the launch train. It does not channel the full launch-train kinetic-energy flow because the energy transfer occurs in the spinning screw's frame of reference. In the screw's frame of reference, the energy transfer is one-half the flywheel's moment of inertia times the square of its relative angular velocity. The flywheel's moment of inertia was calculated in the earlier referenced claim, "Momentum Transfer from the Flywheels, through the Screws, to the Adaptive Nut is Feasible" ...
and the relative angular velocity was calculated to be
Therefore, in the last screw's frame of reference, the energy transferred is
In terms of power, as this energy transfer takes 9 milliseconds, the power is
While this is still a lot of power, it's 222 times less power than the 34.6 GW figure - the rate at which the launch train is gaining kinetic energy at the end of the horizontal acceleration section.
The important point is not that the clutch is easy or low-power. The point is that the clutch only has to manage the relative slip power between two already fast-moving rotating systems, rather than generate the full inertial-frame launch power electromagnetically.
The efficiency of momentum transfer gated by the electromagnetic clutches is also worth calculating. Each flywheel in the final pair of 5 m screw segments generates approximately 1.42 MJ of waste heat during deceleration, giving a combined loss of 2.84 MJ. Over the corresponding 5 m of travel, the launch train gains approximately 15.6 MJ of kinetic energy. The flywheels therefore supply a total of 15.6 + 2.84 = 18.44 MJ. The energy transfer efficiency associated with momentum gating is the useful kinetic-energy gain divided by the total energy supplied:
If we also apply the 1/22 "automotive analogy" factor representing how much braking systems cost relative to drive trains, and an additional admittedly arbitrary "engineering judgment" factor of 0.5 to account for the relaxed design constraints (that is, short operational life, no contaminants, etc.) associated with engineering electromagnetic clutches for the variable pitch screw launcher, then we can ballpark a factor that represents the cost of modulating momentum transfer relative to the cost of directly driving the launch train forward with an electric machine.
Therefore, at least for the last screw segment, modulating momentum transfer from the flywheels to the screws is roughly four orders of magnitude cheaper than directly driving the launch train forward with an electric machine.
The economic advantage comes from moving the energy-conversion step out of the launch event. Electric motors can spin up the flywheels over a much longer period before launch. During launch, the system does not need to convert grid electricity into launch-train kinetic energy at the full instantaneous launch power. It only needs to control the timing and rate of mechanical momentum transfer.
This supports the claim that momentum transfer is cheaper to modulate than the high-power magnetic fields used for electromagnetic acceleration. The evidence is not that electromagnetic clutches are easy or free. The evidence is that the clutch's required heat dissipation and braking power are much, much smaller than the total kinetic-energy acquisition rate of the launch train, and that the clutch acts as a modulator of pre-stored mechanical energy rather than as the primary source of launch power.
One more point needs to be made regarding railguns and quench guns, which may be regarded as exceptions, as they don't behave exactly like other, more conventional, electromagnetic drive systems.
A railgun does not require the same kind of sequentially switched coil system used in many electromagnetic accelerator concepts because the sliding armature itself modulates the electromagnetic interaction as it moves down the rails. However, this does not make the modulation cheap. The armature-rail interface must carry extremely high current while tolerating intense local heating, arcing, erosion, mechanical shock, and plasma formation. These effects produce rapid rail and armature wear, which is one reason railguns have struggled with durability and operating cost. So, even when an electromagnetic accelerator avoids complex field-switching hardware, modulation can still be costly. In railguns, that cost appears as wear and limited operational life.
In quench guns, the cost stems from heavy reliance on superconductors and cryogenic cooling systems, which, at present, remain much more expensive than conventional conductors operated at room temperature.
Reviews
The following reviews are limited in scope to the validity of the claim made above, and do not imply that the reviewer has taken a position regarding any other claim or the overall feasibility of a concept that is supported by this claim.
- 1Verdict: SupportsI have worked with Toyota for 12 years through a variety of roles but for the past 6 years have occupied the position of Product Knowledge and Training Manager. I frequently bridge departments and work between sales, service, and parts to facilitate customer assistance at any level possible, whether that be through technical support or through mechanical diagnosis and repair.
“The braking cost versus drive train cost analysis based on the Toyota Supra checks out”
This is a partial review - I only reviewed the part starting with, “Second, a braking system is cheaper to implement than a drivetrain…“ ending with “… implementing braking power costs roughly 1/22 as much as implementing drivetrain power.” I have confirmed that the cost of parts for both drivetrain and braking systems are accurate and were supplied by our parts department. Additionally I double-checked the performance numbers of the GR86's brakes and found that to be correct. I was initially concerned that the prices listed for the GR86 drive systems seemed remarkably high, but was independently able to verify that other Toyota vehicles can have a transmission (a singular part of the drive system) that costs up to $35,000 without including any other parts of the driveline. The conclusion that the braking system costs roughly 9% of the total drivetrain cost is certainly variable depending on the vehicle in question, but in this case is accurate and reflects a true sense of what I have experienced in my history with Toyota. I support this part of the claim and feel that I'm qualified to review this section.
Submitted:
